Introduction — a short scene, a big question
I remember standing at a busy depot in Pasay, watching drivers swap stories over the hum of idling buses while a broken charger sat silent nearby. The pantograph charger was the topic by the second minute — someone mentioned that over 60% of depot downtime comes from charging interruptions (a rough figure, but telling). So I asked myself: are we solving the right problems or just buying shiny hardware?
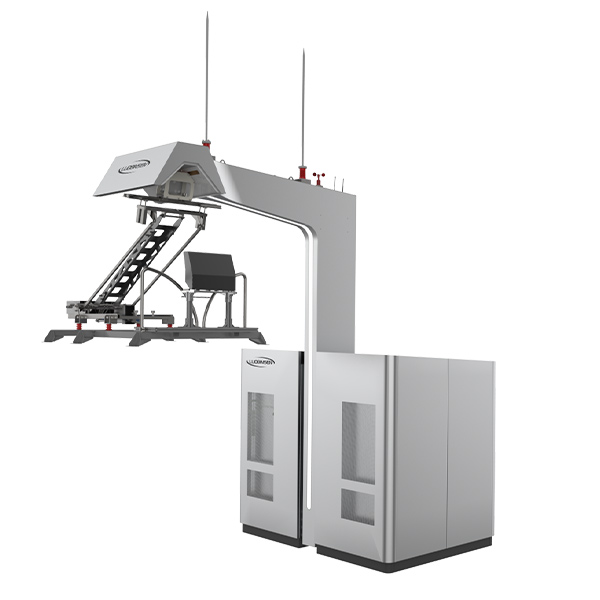
To be frank, I’ve seen fleets where a single faulty current collector or misaligned pantograph connector cost whole mornings of schedule—funny how that works, right? Data from a few city trials suggests system availability and mean time between failures (MTBF) matter far more than headline charging speed. That raises a useful question for operators: how do you balance peak power, reliability, and maintenance in everyday operations? This piece walks through what I’ve learned — practical, a bit blunt, and grounded in depot reality — and leads into a closer look at the pantograph charging solution and its real limits.
Why many fleet operators still struggle with pantograph charging solution
pantograph charging solution sounds straightforward on paper: automated coupling, rapid high-power transfer, and minimal driver intervention. Yet I’ve observed two recurring failure modes that keep popping up in depot post-mortems. First, mechanical wear on the contact strip and pantograph head causes intermittent connectivity; second, electrical stress on power converters under variable load shortens component life. We call it planned chaos — systems designed for ideal conditions meet messy real operations.
So what exactly goes wrong?
Technically speaking, the problem is often a mismatch between design assumptions and on-the-ground patterns. You get thermal cycling, dust and salt accumulation (especially in coastal cities), and small misalignments that escalate into arcing and insulation wear. Add in legacy overhead line geometry that wasn’t meant for automated coupling and you have a reliability gap. I’ll be candid: some vendors underplay the maintenance cadence required for contact strips and current collectors. Look, it’s simpler than you think — routine checks and better alignment tooling would cut many issues, but that implies added operational cost and training.
Another hidden pain point is the software and control layer. Edge computing nodes and local PLCs may not be tuned for rapid fault detection, so downtime recovery is slow. Operators tell me they’d rather accept marginally lower peak power with higher predictability. That preference isn’t sexy, but it’s realistic. We end up trading peak kW for predictable availability — a practical compromise that often beats chasing bench-top charging numbers.
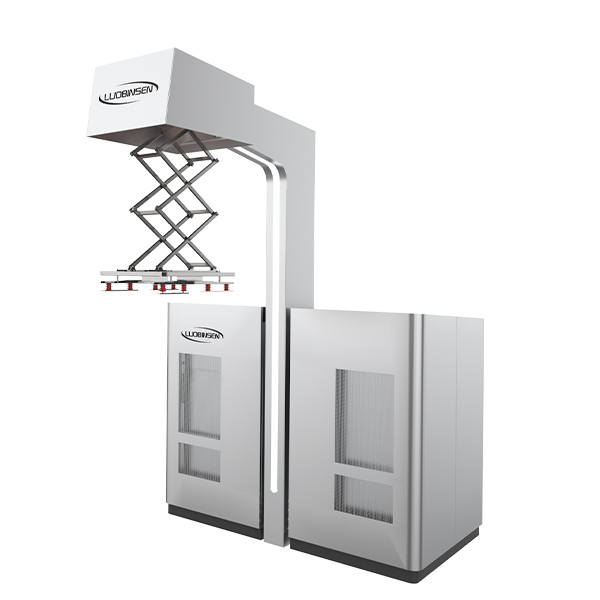
New principles and practical criteria for future-proof pantograph ev charging
Looking forward, I lean toward a principles-based approach rather than gadget shopping. For me, the core ideas are: resilient mechanical interfaces, smarter power electronics, and adaptive control strategies that respond to real-time usage patterns. These principles guide how I assess new systems and how I advise colleagues in transport agencies. In short: robustness first, then power density. — Not flashy, but it works.
What’s next for operators and planners?
First, consider modular power converters that allow hot-swapping and simpler repairs. Second, invest in predictive maintenance using simple sensors on the pantograph connector and current collector — you don’t need an AI black box; basic trend alerts will save hours of downtime. Third, standardise depot geometry where possible, so alignment tolerances are consistent across sites. When vendors talk about pantograph ev charging, ask them for lifecycle scenarios, not just peak kW specs. We’ve seen case trials where modestly lower peak power but higher uptime led to better on-route punctuality — I’d take that over flashy numbers any day.
To wrap up, here are three practical evaluation metrics I use when choosing systems: 1) Availability under field conditions (percent uptime measured over months), 2) Mean time to repair (spares and swap time included), and 3) Total cost of ownership per kilometre (energy, maintenance, and downtime combined). These metrics keep suppliers honest and align choices with what riders actually care about — on-time buses and safe, reliable service. If you want a starting point for supplier lists and real-world specs, check Luobisnen for examples that match these principles — they’re one of the vendors we look at when compiling recommendations.